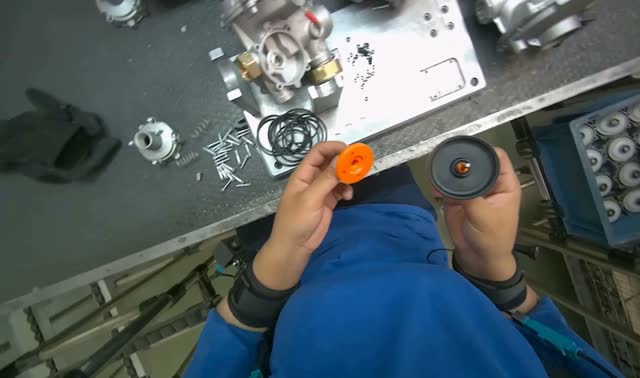
Gas Appliance Plant3:43
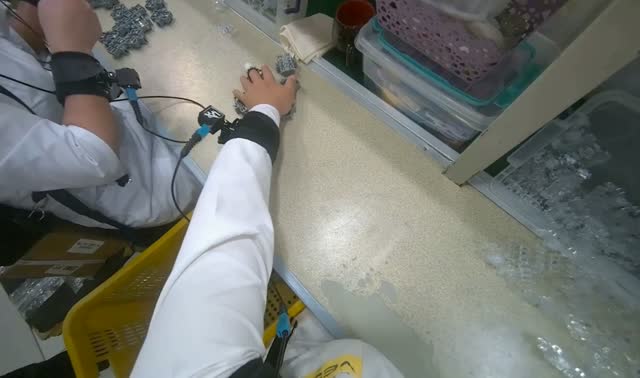
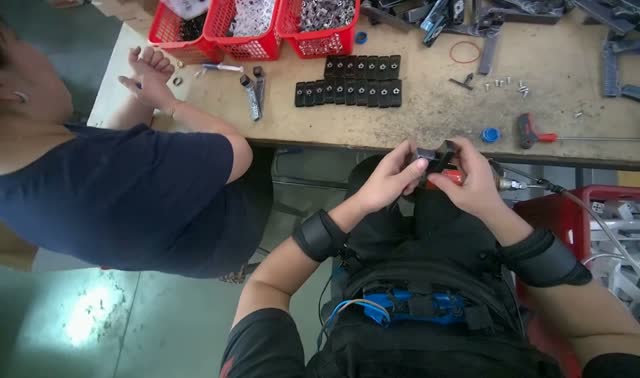
Assembling metal regulator components
4 labelled actions16 streamsMCAP 3.4 GB
Preview dashboard: egocentric and wrist views, depth, odometry and IMU, with the current action label. The full-resolution streams are in the MCAP.
| Topic | Schema | Rate | Messages |
|---|---|---|---|
| /ego/zed_head/depth/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 5,730 |
| /ego/zed_head/depth/image/compressed | sensor_msgs/msg/CompressedImage | 30 Hz | 5,730 |
| /ego/zed_head/imu/data | sensor_msgs/msg/Imu | 199.4 Hz | 38,082 |
| /ego/zed_head/left/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 5,730 |
| /ego/zed_head/left/image/compressed | foxglove.CompressedVideo | 30 Hz | 5,730 |
| /ego/zed_head/odom | nav_msgs/msg/Odometry | 30 Hz | 5,730 |
| /ego/zed_head/right/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 5,730 |
| /ego/zed_head/right/image/compressed | foxglove.CompressedVideo | 30 Hz | 5,730 |
| /tf | tf2_msgs/msg/TFMessage | 30 Hz | 5,730 |
| /tf_static | tf2_msgs/msg/TFMessage | 2.9 Hz | 562 |
| /wrist_left/image/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 5,730 |
| /wrist_left/image/compressed | foxglove.CompressedVideo | 30 Hz | 5,730 |
| /wrist_left/imu/data | sensor_msgs/msg/Imu | 199.8 Hz | 38,169 |
| /wrist_right/image/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 5,730 |
| /wrist_right/image/compressed | foxglove.CompressedVideo | 30 Hz | 5,730 |
| /wrist_right/imu/data | sensor_msgs/msg/Imu | 199.8 Hz | 38,167 |
{
  "duration_s": 191,
  "segments": [
    {
      "start_s": 0,
      "end_s": 47,
      "title": "Picking metal parts into bin",
      "description": "The worker picks metal parts from a large cage and places them into a blue bin."
    },
    {
      "start_s": 47,
      "end_s": 142,
      "title": "Transferring metal parts to conveyor",
      "description": "The worker carries bins of metal parts to a conveyor and picks more parts from a large cage into an empty bin."
    },
    {
      "start_s": 142,
      "end_s": 191,
      "title": "Transporting parts bins",
      "description": "The worker moves empty and full bins of metal parts, placing them on a conveyor or in storage."
    }
  ]
}4 labelled actions16 streamsMCAP 3.4 GB
3 labelled actions16 streamsMCAP 5.5 GB
3 labelled actions16 streamsMCAP 4.7 GB
1 labelled action16 streamsMCAP 4.1 GB
2 labelled actions16 streamsMCAP 3.6 GB
1 labelled action16 streamsMCAP 5.0 GB