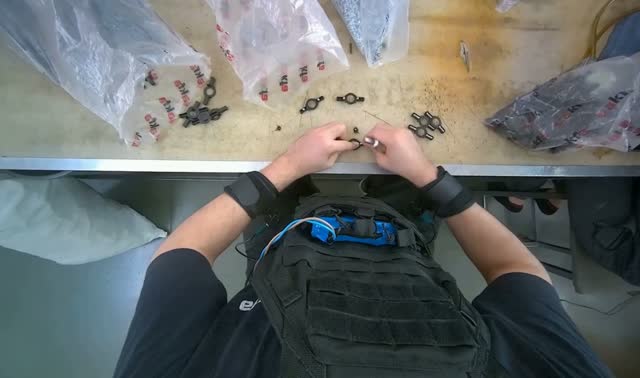
Door & Window Hardware Plant4:23
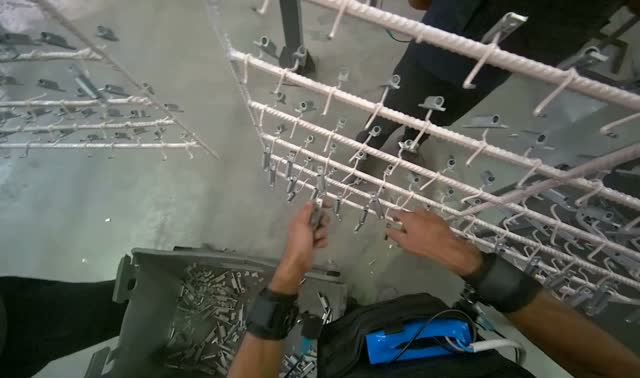
Assembling small black components with pins
1 labelled action16 streamsMCAP 4.1 GB
Preview dashboard: egocentric and wrist views, depth, odometry and IMU, with the current action label. The full-resolution streams are in the MCAP.
| Topic | Schema | Rate | Messages |
|---|---|---|---|
| /ego/zed_head/depth/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 6,630 |
| /ego/zed_head/depth/image/compressed | sensor_msgs/msg/CompressedImage | 30 Hz | 6,630 |
| /ego/zed_head/imu/data | sensor_msgs/msg/Imu | 198.2 Hz | 43,807 |
| /ego/zed_head/left/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 6,630 |
| /ego/zed_head/left/image/compressed | foxglove.CompressedVideo | 30 Hz | 6,630 |
| /ego/zed_head/odom | nav_msgs/msg/Odometry | 30 Hz | 6,630 |
| /ego/zed_head/right/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 6,630 |
| /ego/zed_head/right/image/compressed | foxglove.CompressedVideo | 30 Hz | 6,630 |
| /tf | tf2_msgs/msg/TFMessage | 30 Hz | 6,630 |
| /tf_static | tf2_msgs/msg/TFMessage | 2.9 Hz | 649 |
| /wrist_left/image/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 6,630 |
| /wrist_left/image/compressed | foxglove.CompressedVideo | 30 Hz | 6,630 |
| /wrist_left/imu/data | sensor_msgs/msg/Imu | 198.2 Hz | 43,812 |
| /wrist_right/image/camera_info | sensor_msgs/msg/CameraInfo | 30 Hz | 6,630 |
| /wrist_right/image/compressed | foxglove.CompressedVideo | 30 Hz | 6,630 |
| /wrist_right/imu/data | sensor_msgs/msg/Imu | 198.6 Hz | 43,883 |
{
  "duration_s": 221,
  "segments": [
    {
      "start_s": 0,
      "end_s": 131,
      "title": "Packaging and boxing handles",
      "description": "The worker continues the repetitive task of packaging white window handles into plastic bags. They pick up two handles, place them on a plastic sheet, seal the bag, and then place the packaged handles into a cardboard box with dividers. A brief pause to fetch more plastic bags is included in this continuous activity."
    },
    {
      "start_s": 131,
      "end_s": 133,
      "title": "Idle"
    },
    {
      "start_s": 133,
      "end_s": 221,
      "title": "Packaging handles into plastic bags",
      "description": "The worker gathers white handles and small bags of fasteners from various bins, brings them to the workstation table, and then proceeds to place the handles into the plastic bags."
    }
  ]
}1 labelled action16 streamsMCAP 4.1 GB
1 labelled action16 streamsMCAP 7.4 GB
2 labelled actions16 streamsMCAP 5.7 GB
3 labelled actions16 streamsMCAP 4.6 GB
1 labelled action16 streamsMCAP 5.5 GB
5 labelled actions16 streamsMCAP 5.1 GB