Skip to content

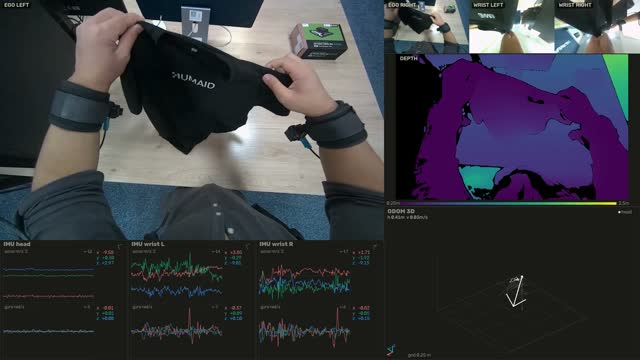
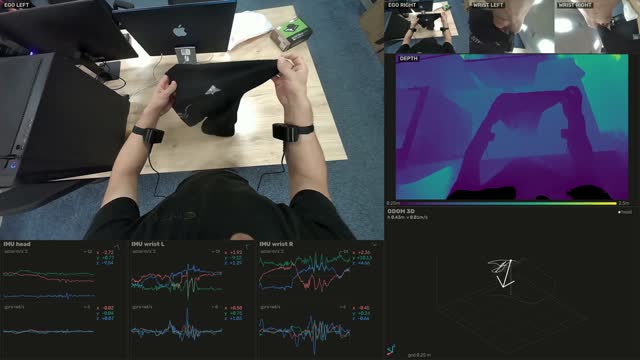
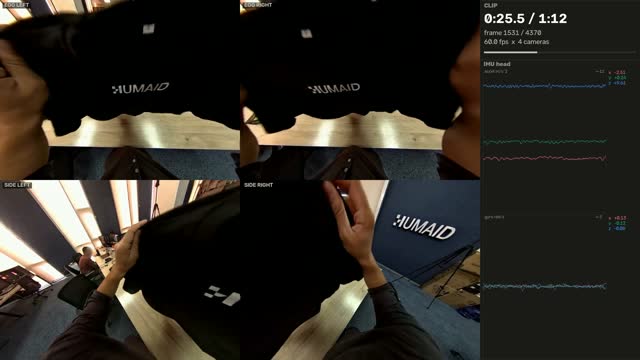
Preview dashboard of every stream the rig records. The full-resolution streams are in the MCAP.

Rig & sensors

Video H.264 · Depth PNG · 16UC1 · mm

Left gripper

Handheld parallel-jaw gripper with a fisheye camera, an RGB-D camera, an IMU and externally tracked pose

Left gripper cameras
CameraTypeResolutionRateFOV
FisheyeRGB · fisheye1280×96030 fps130°×116°
RGB-DRGB1280×72030 fps89°×58°
DepthDepth · stereo matching1280×72030 fps89°×58°
IMU
250 Hz
Pose
External optical tracking (two base stations) · 93 Hz
Joints
Jaw angle, Jaw opening · 93 Hz

Right gripper

Handheld parallel-jaw gripper with a fisheye camera, an RGB-D camera, an IMU and externally tracked pose

Right gripper cameras
CameraTypeResolutionRateFOV
FisheyeRGB · fisheye1280×96030 fps130°×116°
RGB-DRGB1280×72030 fps89°×58°
DepthDepth · stereo matching1280×72030 fps90°×58°
IMU
249 Hz
Pose
External optical tracking (two base stations) · 93 Hz
Joints
Jaw angle, Jaw opening · 93 Hz

Sensor streams in the MCAP

20 topics
MCAP topics, message schemas and rates
TopicSchemaRateMessages
/gripper_left/fisheye/camera_infosensor_msgs/msg/CameraInfo30 Hz1,447
/gripper_left/fisheye/image/compressedfoxglove.CompressedVideo30 Hz1,447
/gripper_left/imu/datasensor_msgs/msg/Imu250 Hz12,054
/gripper_left/joint_statessensor_msgs/msg/JointState92.7 Hz4,470
/gripper_left/odomnav_msgs/msg/Odometry92.7 Hz4,470
/gripper_left/rgbd/color/camera_infosensor_msgs/msg/CameraInfo29.6 Hz1,426
/gripper_left/rgbd/color/image/compressedfoxglove.CompressedVideo29.6 Hz1,426
/gripper_left/rgbd/depth/camera_infosensor_msgs/msg/CameraInfo29.6 Hz1,426
/gripper_left/rgbd/depth/image/compressedsensor_msgs/msg/CompressedImage29.6 Hz1,426
/gripper_right/fisheye/camera_infosensor_msgs/msg/CameraInfo30 Hz1,447
/gripper_right/fisheye/image/compressedfoxglove.CompressedVideo30 Hz1,447
/gripper_right/imu/datasensor_msgs/msg/Imu249.2 Hz12,019
/gripper_right/joint_statessensor_msgs/msg/JointState92.7 Hz4,471
/gripper_right/odomnav_msgs/msg/Odometry92.7 Hz4,471
/gripper_right/rgbd/color/camera_infosensor_msgs/msg/CameraInfo29.7 Hz1,431
/gripper_right/rgbd/color/image/compressedfoxglove.CompressedVideo29.7 Hz1,431
/gripper_right/rgbd/depth/camera_infosensor_msgs/msg/CameraInfo29.7 Hz1,431
/gripper_right/rgbd/depth/image/compressedsensor_msgs/msg/CompressedImage29.7 Hz1,431
/tftf2_msgs/msg/TFMessage185.4 Hz8,941
/tf_statictf2_msgs/msg/TFMessage1 Hz49

Metadata

d521c4eeb082542494786da77127cecd.json
{
  "schema_version": 2,
  "recording": {
    "rig": "UMI_Gripper",
    "task": "T-Shirt_Folding",
    "duration_s": 48.221
  },
  "rig": {
    "units": {
      "gripper_left": {
        "description": "handheld parallel-jaw gripper with a fisheye camera, an RGB-D camera, an IMU and externally tracked pose",
        "cameras": {
          "fisheye": {
            "kind": "color",
            "lens": "fisheye",
            "resolution": [
              1280,
              960
            ],
            "fps_nominal": 30,
            "fps_measured": 30.009,
            "frames": 1447,
            "fov_deg": {
              "horizontal": 130,
              "vertical": 116.3
            },
            "rectified": true,
            "topic": "/gripper_left/fisheye/image/compressed",
            "camera_info": "/gripper_left/fisheye/camera_info",
            "frame_id": "gripper_left_fisheye_optical_frame"
          },
          "color": {
            "kind": "color",
            "lens": "pinhole",
            "resolution": [
              1280,
              720
            ],
            "fps_nominal": 30,
            "fps_measured": 29.58,
            "frames": 1426,
            "fov_deg": {
              "horizontal": 89.4,
              "vertical": 58.2
            },
            "rectified": false,
            "topic": "/gripper_left/rgbd/color/image/compressed",
            "camera_info": "/gripper_left/rgbd/color/camera_info",
            "frame_id": "gripper_left_rgbd_color_optical_frame"
          },
          "depth": {
            "kind": "depth",
            "lens": "pinhole",
            "resolution": [
              1280,
              720
            ],
            "fps_nominal": 30,
            "fps_measured": 29.58,
            "frames": 1426,
            "fov_deg": {
              "horizontal": 89.3,
              "vertical": 58.1
            },
            "rectified": true,
            "depth_method": "stereo matching",
            "units": "mm",
            "topic": "/gripper_left/rgbd/depth/image/compressed",
            "camera_info": "/gripper_left/rgbd/depth/camera_info",
            "frame_id": "gripper_left_rgbd_depth_optical_frame"
          }
        },
        "imu": {
          "topic": "/gripper_left/imu/data",
          "frame_id": "gripper_left_imu_link",
          "rate_hz": 249.961,
          "units": {
            "linear_acceleration": "m/s^2 (converted from g)",
            "angular_velocity": "rad/s"
          }
        },
        "odometry": {
          "topic": "/gripper_left/odom",
          "frame_id": "world",
          "child_frame_id": "gripper_left_tcp",
          "source": "external optical tracking (two base stations)",
          "point": "tool centre point between the finger tips",
          "rate_hz": 92.713
        },
        "joints": {
          "topic": "/gripper_left/joint_states",
          "names": [
            "gripper_left_jaw_angle",
            "gripper_left_jaw_opening"
          ],
          "units": [
            "rad from fully closed",
            "m between finger pads"
          ],
          "rate_hz": 92.713,
          "jaw_travel_deg": 99.481
        }
      },
      "gripper_right": {
        "description": "handheld parallel-jaw gripper with a fisheye camera, an RGB-D camera, an IMU and externally tracked pose",
        "cameras": {
          "fisheye": {
            "kind": "color",
            "lens": "fisheye",
            "resolution": [
              1280,
              960
            ],
            "fps_nominal": 30,
            "fps_measured": 29.987,
            "frames": 1447,
            "fov_deg": {
              "horizontal": 130,
              "vertical": 116.3
            },
            "rectified": true,
            "topic": "/gripper_right/fisheye/image/compressed",
            "camera_info": "/gripper_right/fisheye/camera_info",
            "frame_id": "gripper_right_fisheye_optical_frame"
          },
          "color": {
            "kind": "color",
            "lens": "pinhole",
            "resolution": [
              1280,
              720
            ],
            "fps_nominal": 30,
            "fps_measured": 29.662,
            "frames": 1431,
            "fov_deg": {
              "horizontal": 89,
              "vertical": 58
            },
            "rectified": false,
            "topic": "/gripper_right/rgbd/color/image/compressed",
            "camera_info": "/gripper_right/rgbd/color/camera_info",
            "frame_id": "gripper_right_rgbd_color_optical_frame"
          },
          "depth": {
            "kind": "depth",
            "lens": "pinhole",
            "resolution": [
              1280,
              720
            ],
            "fps_nominal": 30,
            "fps_measured": 29.662,
            "frames": 1431,
            "fov_deg": {
              "horizontal": 89.7,
              "vertical": 58.4
            },
            "rectified": true,
            "depth_method": "stereo matching",
            "units": "mm",
            "topic": "/gripper_right/rgbd/depth/image/compressed",
            "camera_info": "/gripper_right/rgbd/depth/camera_info",
            "frame_id": "gripper_right_rgbd_depth_optical_frame"
          }
        },
        "imu": {
          "topic": "/gripper_right/imu/data",
          "frame_id": "gripper_right_imu_link",
          "rate_hz": 249.246,
          "units": {
            "linear_acceleration": "m/s^2 (converted from g)",
            "angular_velocity": "rad/s"
          }
        },
        "odometry": {
          "topic": "/gripper_right/odom",
          "frame_id": "world",
          "child_frame_id": "gripper_right_tcp",
          "source": "external optical tracking (two base stations)",
          "point": "tool centre point between the finger tips",
          "rate_hz": 92.719
        },
        "joints": {
          "topic": "/gripper_right/joint_states",
          "names": [
            "gripper_right_jaw_angle",
            "gripper_right_jaw_opening"
          ],
          "units": [
            "rad from fully closed",
            "m between finger pads"
          ],
          "rate_hz": 92.719,
          "jaw_travel_deg": 99.322
        }
      }
    },
    "conventions": {
      "units": "SI (m, rad, s); depth PNGs in millimetres",
      "frames": "REP-103: *_camera_link / odom x-forward y-left z-up; *_optical_frame z-forward x-right y-down"
    }
  },
  "format": {
    "container": {
      "format": "MCAP",
      "profile": "ros2",
      "channels": 20,
      "messages": 68161
    },
    "encoding": {
      "video": {
        "codec": [
          "h264"
        ]
      },
      "depth": {
        "format": "png",
        "pixel": "16UC1",
        "units": "mm",
        "invalid_value": 0
      }
    },
    "channels": [
      {
        "topic": "/gripper_left/fisheye/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1447,
        "rate_hz": 30.009,
        "frame_id": "gripper_left_fisheye_optical_frame"
      },
      {
        "topic": "/gripper_left/fisheye/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 1447,
        "rate_hz": 30.009,
        "frame_id": "gripper_left_fisheye_optical_frame",
        "width": 1280,
        "height": 960,
        "codec": "h264"
      },
      {
        "topic": "/gripper_left/imu/data",
        "schema": "sensor_msgs/msg/Imu",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 12054,
        "rate_hz": 249.961,
        "frame_id": "gripper_left_imu_link"
      },
      {
        "topic": "/gripper_left/joint_states",
        "schema": "sensor_msgs/msg/JointState",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 4470,
        "rate_hz": 92.713
      },
      {
        "topic": "/gripper_left/odom",
        "schema": "nav_msgs/msg/Odometry",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 4470,
        "rate_hz": 92.713,
        "frame_id": "world"
      },
      {
        "topic": "/gripper_left/rgbd/color/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1426,
        "rate_hz": 29.58,
        "frame_id": "gripper_left_rgbd_color_optical_frame"
      },
      {
        "topic": "/gripper_left/rgbd/color/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 1426,
        "rate_hz": 29.58,
        "frame_id": "gripper_left_rgbd_color_optical_frame",
        "width": 1280,
        "height": 720,
        "codec": "h264"
      },
      {
        "topic": "/gripper_left/rgbd/depth/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1426,
        "rate_hz": 29.58,
        "frame_id": "gripper_left_rgbd_depth_optical_frame"
      },
      {
        "topic": "/gripper_left/rgbd/depth/image/compressed",
        "schema": "sensor_msgs/msg/CompressedImage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1426,
        "rate_hz": 29.58,
        "frame_id": "gripper_left_rgbd_depth_optical_frame",
        "width": 1280,
        "height": 720,
        "format": "png"
      },
      {
        "topic": "/gripper_right/fisheye/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1447,
        "rate_hz": 29.987,
        "frame_id": "gripper_right_fisheye_optical_frame"
      },
      {
        "topic": "/gripper_right/fisheye/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 1447,
        "rate_hz": 29.987,
        "frame_id": "gripper_right_fisheye_optical_frame",
        "width": 1280,
        "height": 960,
        "codec": "h264"
      },
      {
        "topic": "/gripper_right/imu/data",
        "schema": "sensor_msgs/msg/Imu",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 12019,
        "rate_hz": 249.246,
        "frame_id": "gripper_right_imu_link"
      },
      {
        "topic": "/gripper_right/joint_states",
        "schema": "sensor_msgs/msg/JointState",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 4471,
        "rate_hz": 92.719
      },
      {
        "topic": "/gripper_right/odom",
        "schema": "nav_msgs/msg/Odometry",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 4471,
        "rate_hz": 92.719,
        "frame_id": "world"
      },
      {
        "topic": "/gripper_right/rgbd/color/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1431,
        "rate_hz": 29.662,
        "frame_id": "gripper_right_rgbd_color_optical_frame"
      },
      {
        "topic": "/gripper_right/rgbd/color/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 1431,
        "rate_hz": 29.662,
        "frame_id": "gripper_right_rgbd_color_optical_frame",
        "width": 1280,
        "height": 720,
        "codec": "h264"
      },
      {
        "topic": "/gripper_right/rgbd/depth/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1431,
        "rate_hz": 29.662,
        "frame_id": "gripper_right_rgbd_depth_optical_frame"
      },
      {
        "topic": "/gripper_right/rgbd/depth/image/compressed",
        "schema": "sensor_msgs/msg/CompressedImage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 1431,
        "rate_hz": 29.662,
        "frame_id": "gripper_right_rgbd_depth_optical_frame",
        "width": 1280,
        "height": 720,
        "format": "png"
      },
      {
        "topic": "/tf",
        "schema": "tf2_msgs/msg/TFMessage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 8941,
        "rate_hz": 185.437
      },
      {
        "topic": "/tf_static",
        "schema": "tf2_msgs/msg/TFMessage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 49,
        "rate_hz": 1
      }
    ]
  },
  "render": {
    "width": 2560,
    "height": 1440,
    "fps": 30.009,
    "codec": "h264",
    "duration_s": 48.22
  }
}