Skip to content

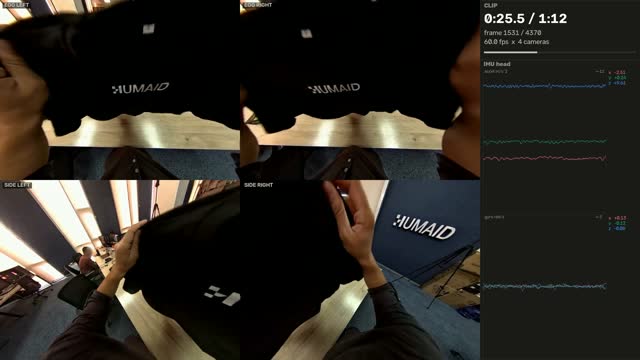
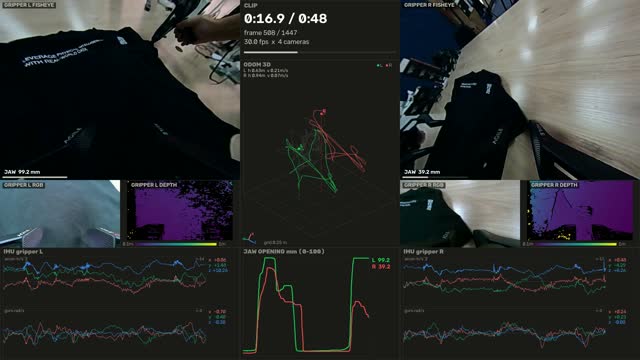
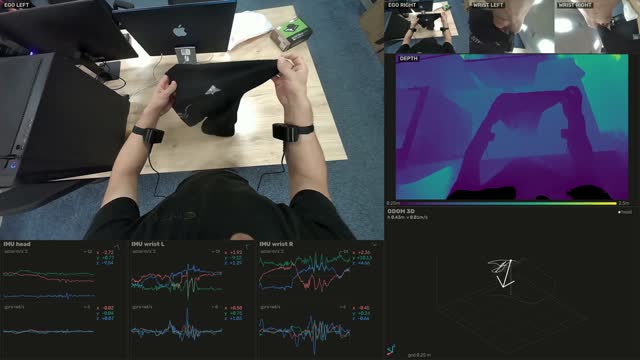
Preview dashboard of every stream the rig records. The full-resolution streams are in the MCAP.

Rig & sensors

Video H.264 · Depth PNG · 16UC1 · mm

Head

Head-mounted stereo camera with depth, IMU and on-camera visual-inertial odometry

Stereo baseline 120 mm

Head cameras
CameraTypeResolutionRateFOV
LeftRGB1920×120030 fps105°×79°
RightRGB1920×120030 fps105°×79°
DepthDepth · learned stereo matching1920×120030 fps105°×79°
IMU
200 Hz
Pose
Visual-inertial odometry on the camera · 30 Hz
Left wrist

Wrist-mounted camera with IMU

Left wrist cameras
CameraTypeResolutionRateFOV
CameraRGB1920×120030 fps141°×121°
IMU
200 Hz

Right wrist

Wrist-mounted camera with IMU

Right wrist cameras
CameraTypeResolutionRateFOV
CameraRGB1920×120030 fps141°×121°
IMU
200 Hz

Sensor streams in the MCAP

16 topics
MCAP topics, message schemas and rates
TopicSchemaRateMessages
/ego/zed_head/depth/camera_infosensor_msgs/msg/CameraInfo29.8 Hz2,238
/ego/zed_head/depth/image/compressedsensor_msgs/msg/CompressedImage29.8 Hz2,238
/ego/zed_head/imu/datasensor_msgs/msg/Imu199.8 Hz15,026
/ego/zed_head/left/camera_infosensor_msgs/msg/CameraInfo29.8 Hz2,238
/ego/zed_head/left/image/compressedfoxglove.CompressedVideo29.8 Hz2,238
/ego/zed_head/odomnav_msgs/msg/Odometry29.8 Hz2,238
/ego/zed_head/right/camera_infosensor_msgs/msg/CameraInfo29.8 Hz2,238
/ego/zed_head/right/image/compressedfoxglove.CompressedVideo29.8 Hz2,238
/tftf2_msgs/msg/TFMessage29.8 Hz2,238
/tf_statictf2_msgs/msg/TFMessage2.9 Hz221
/wrist_left/image/camera_infosensor_msgs/msg/CameraInfo29.8 Hz2,242
/wrist_left/image/compressedfoxglove.CompressedVideo29.8 Hz2,242
/wrist_left/imu/datasensor_msgs/msg/Imu200.3 Hz15,060
/wrist_right/image/camera_infosensor_msgs/msg/CameraInfo29.8 Hz2,239
/wrist_right/image/compressedfoxglove.CompressedVideo29.8 Hz2,239
/wrist_right/imu/datasensor_msgs/msg/Imu199.6 Hz15,008

Metadata

b9efc75e8be955b7b6991c1ed47270c7.json
{
  "schema_version": 2,
  "recording": {
    "rig": "Head_Wrist_Rig_1",
    "task": "T-Shirt_Folding",
    "duration_s": 75.205
  },
  "rig": {
    "units": {
      "ego": {
        "description": "head-mounted stereo camera with depth, IMU and on-camera visual-inertial odometry",
        "stereo_pair": [
          "left",
          "right"
        ],
        "stereo_baseline_m": 0.11995,
        "cameras": {
          "left": {
            "kind": "color",
            "lens": "pinhole",
            "resolution": [
              1920,
              1200
            ],
            "fps_nominal": 30,
            "fps_measured": 29.757,
            "frames": 2238,
            "fov_deg": {
              "horizontal": 105.3,
              "vertical": 78.6
            },
            "rectified": true,
            "topic": "/ego/zed_head/left/image/compressed",
            "camera_info": "/ego/zed_head/left/camera_info",
            "frame_id": "zed_head_left_camera_optical_frame"
          },
          "right": {
            "kind": "color",
            "lens": "pinhole",
            "resolution": [
              1920,
              1200
            ],
            "fps_nominal": 30,
            "fps_measured": 29.757,
            "frames": 2238,
            "fov_deg": {
              "horizontal": 105.3,
              "vertical": 78.6
            },
            "rectified": true,
            "topic": "/ego/zed_head/right/image/compressed",
            "camera_info": "/ego/zed_head/right/camera_info",
            "frame_id": "zed_head_right_camera_optical_frame"
          },
          "depth": {
            "kind": "depth",
            "lens": "pinhole",
            "resolution": [
              1920,
              1200
            ],
            "fps_nominal": 30,
            "fps_measured": 29.757,
            "frames": 2238,
            "fov_deg": {
              "horizontal": 105.3,
              "vertical": 78.6
            },
            "rectified": true,
            "depth_method": "learned stereo matching",
            "units": "mm",
            "topic": "/ego/zed_head/depth/image/compressed",
            "camera_info": "/ego/zed_head/depth/camera_info",
            "frame_id": "zed_head_depth_camera_optical_frame"
          }
        },
        "imu": {
          "topic": "/ego/zed_head/imu/data",
          "frame_id": "zed_head_imu_link",
          "rate_hz": 199.793,
          "units": {
            "linear_acceleration": "m/s^2",
            "angular_velocity": "rad/s"
          }
        },
        "odometry": {
          "topic": "/ego/zed_head/odom",
          "frame_id": "odom",
          "child_frame_id": "zed_head_camera_link",
          "source": "visual-inertial odometry on the camera",
          "rate_hz": 29.757
        }
      },
      "wrist_left": {
        "description": "wrist-mounted camera with IMU",
        "cameras": {
          "image": {
            "kind": "color",
            "lens": "pinhole",
            "resolution": [
              1920,
              1200
            ],
            "fps_nominal": 30,
            "fps_measured": 29.823,
            "frames": 2242,
            "fov_deg": {
              "horizontal": 140.8,
              "vertical": 120.6
            },
            "rectified": true,
            "topic": "/wrist_left/image/compressed",
            "camera_info": "/wrist_left/image/camera_info",
            "frame_id": "wrist_left_optical_frame"
          }
        },
        "imu": {
          "topic": "/wrist_left/imu/data",
          "frame_id": "wrist_left_imu_link",
          "rate_hz": 200.259,
          "units": {
            "linear_acceleration": "m/s^2",
            "angular_velocity": "rad/s"
          }
        }
      },
      "wrist_right": {
        "description": "wrist-mounted camera with IMU",
        "cameras": {
          "image": {
            "kind": "color",
            "lens": "pinhole",
            "resolution": [
              1920,
              1200
            ],
            "fps_nominal": 30,
            "fps_measured": 29.783,
            "frames": 2239,
            "fov_deg": {
              "horizontal": 140.9,
              "vertical": 120.9
            },
            "rectified": true,
            "topic": "/wrist_right/image/compressed",
            "camera_info": "/wrist_right/image/camera_info",
            "frame_id": "wrist_right_optical_frame"
          }
        },
        "imu": {
          "topic": "/wrist_right/imu/data",
          "frame_id": "wrist_right_imu_link",
          "rate_hz": 199.563,
          "units": {
            "linear_acceleration": "m/s^2",
            "angular_velocity": "rad/s"
          }
        }
      }
    },
    "conventions": {
      "units": "SI (m, rad, s); depth PNGs in millimetres",
      "frames": "REP-103: *_camera_link / odom x-forward y-left z-up; *_optical_frame z-forward x-right y-down"
    }
  },
  "format": {
    "container": {
      "format": "MCAP",
      "profile": "ros2",
      "channels": 16,
      "messages": 72181
    },
    "encoding": {
      "video": {
        "codec": [
          "h264"
        ]
      },
      "depth": {
        "format": "png",
        "pixel": "16UC1",
        "units": "mm",
        "invalid_value": 0
      }
    },
    "channels": [
      {
        "topic": "/ego/zed_head/depth/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "zed_head_depth_camera_optical_frame"
      },
      {
        "topic": "/ego/zed_head/depth/image/compressed",
        "schema": "sensor_msgs/msg/CompressedImage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "zed_head_depth_camera_optical_frame",
        "width": 1920,
        "height": 1200,
        "format": "png"
      },
      {
        "topic": "/ego/zed_head/imu/data",
        "schema": "sensor_msgs/msg/Imu",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 15026,
        "rate_hz": 199.793,
        "frame_id": "zed_head_imu_link"
      },
      {
        "topic": "/ego/zed_head/left/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "zed_head_left_camera_optical_frame"
      },
      {
        "topic": "/ego/zed_head/left/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "zed_head_left_camera_optical_frame",
        "width": 1920,
        "height": 1200,
        "codec": "h264"
      },
      {
        "topic": "/ego/zed_head/odom",
        "schema": "nav_msgs/msg/Odometry",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "odom"
      },
      {
        "topic": "/ego/zed_head/right/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "zed_head_right_camera_optical_frame"
      },
      {
        "topic": "/ego/zed_head/right/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 2238,
        "rate_hz": 29.757,
        "frame_id": "zed_head_right_camera_optical_frame",
        "width": 1920,
        "height": 1200,
        "codec": "h264"
      },
      {
        "topic": "/tf",
        "schema": "tf2_msgs/msg/TFMessage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2238,
        "rate_hz": 29.757
      },
      {
        "topic": "/tf_static",
        "schema": "tf2_msgs/msg/TFMessage",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 221,
        "rate_hz": 2.94
      },
      {
        "topic": "/wrist_left/image/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2242,
        "rate_hz": 29.823,
        "frame_id": "wrist_left_optical_frame"
      },
      {
        "topic": "/wrist_left/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 2242,
        "rate_hz": 29.823,
        "frame_id": "wrist_left_optical_frame",
        "width": 1920,
        "height": 1200,
        "codec": "h264"
      },
      {
        "topic": "/wrist_left/imu/data",
        "schema": "sensor_msgs/msg/Imu",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 15060,
        "rate_hz": 200.259,
        "frame_id": "wrist_left_imu_link"
      },
      {
        "topic": "/wrist_right/image/camera_info",
        "schema": "sensor_msgs/msg/CameraInfo",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 2239,
        "rate_hz": 29.783,
        "frame_id": "wrist_right_optical_frame"
      },
      {
        "topic": "/wrist_right/image/compressed",
        "schema": "foxglove.CompressedVideo",
        "schema_encoding": "protobuf",
        "message_encoding": "protobuf",
        "messages": 2239,
        "rate_hz": 29.783,
        "frame_id": "wrist_right_optical_frame",
        "width": 1920,
        "height": 1200,
        "codec": "h264"
      },
      {
        "topic": "/wrist_right/imu/data",
        "schema": "sensor_msgs/msg/Imu",
        "schema_encoding": "ros2msg",
        "message_encoding": "cdr",
        "messages": 15008,
        "rate_hz": 199.563,
        "frame_id": "wrist_right_imu_link"
      }
    ]
  },
  "render": {
    "width": 2560,
    "height": 1440,
    "fps": 29.757,
    "codec": "h264",
    "duration_s": 75.176
  }
}