Head
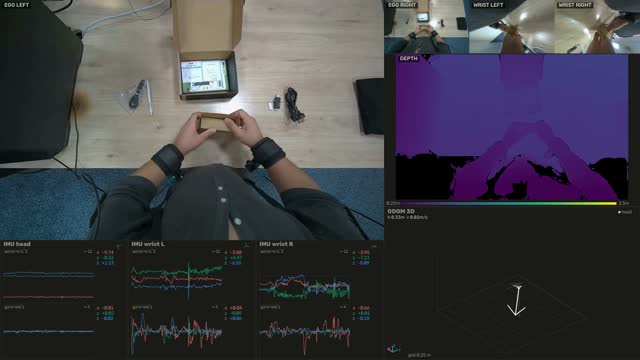
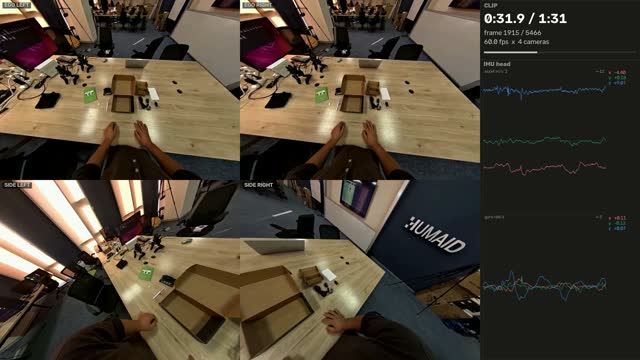
Head-mounted stereo camera with IMU and magnetometer; depth and visual odometry computed from the stereo pair at conversion
Stereo baseline 60 mm
| Camera | Type | Resolution | Rate | FOV |
|---|---|---|---|---|
| Left | RGB | 1920×1200 | 30 fps | 111°×84° |
| Right | RGB | 1920×1200 | 30 fps | 111°×84° |
| Depth | Depth · learned stereo matching · 0.25–12 m | 1920×1200 | 30 fps | 111°×84° |
- IMU
- 500 Hz
- Pose
- Stereo visual odometry (feature tracking + PnP, gyro rotation prior), computed at conversion · 30 Hz
- Magnetometer
- 100 Hz